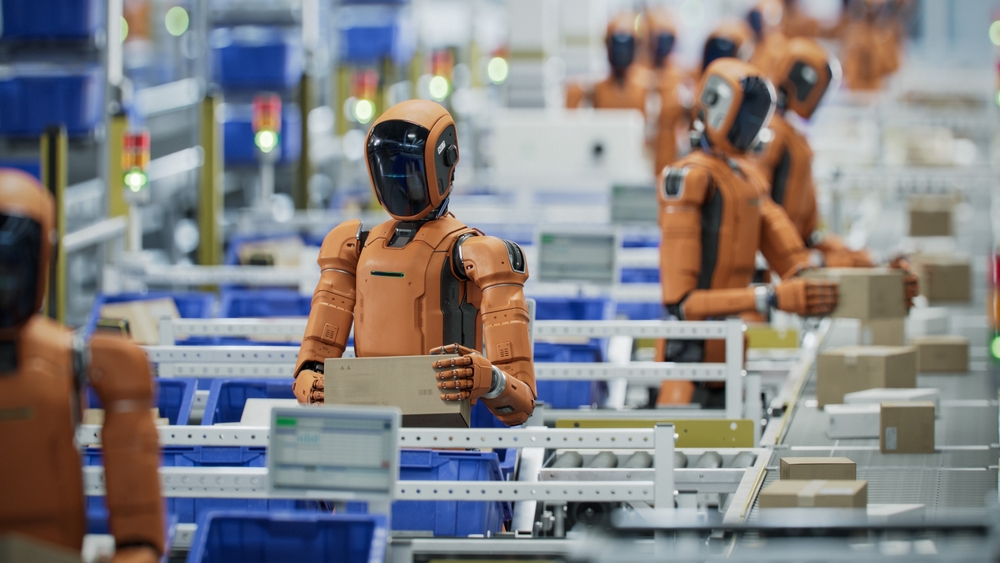
Understand the behavior of any robot in real time.
Decisions
A robot makes thousands of decisions a shift.
Complexity
Understanding how a robot thinks is complex, iterative and time‑consuming.
Decisions
A robot makes thousands of decisions a shift.
Complexity
Understanding how a robot thinks is complex, iterative and time‑consuming.
Every run carries its own evidence. Every failure arrives with its cause attached.
- 4
- SDK entry points:
task,decision,controller_switch,fault - 1
- required dependency:
opentelemetry-api - 0
- changes to your robot's control logic
How it works
An open convention.
An easy to use SDK.
An engine that never forgets.
with momentum.task("pick_place"):
  momentum.decision(
    type="grasp_selection",
    confidence=result.confidence)
Instrumentmomentum-sdk, next to code you already trust
Evidencestructured traces, every source attached
Momentum agentexplores the evidence when a run fails
✗ fault detectedrun #4412
Root cause — grasp_selection
Confidence collapsed to 0.62 on a reflective part; verification then passed a misplaced piece.
Fix — gate grasps below 0.75 · re-run verification
evidence: 14 traces cited →Root cause & fixranked, evidence-backed, in seconds
SDK
Up and running before your coffee's cold.
Add momentum.* calls next to the code you already have. We handle the serialization, the attribute naming, the span lifecycle: you keep total control over what your robot actually does.
import momentum_sdk as momentum

# Root span — the task the robot was asked to perform
with momentum.task("pick_and_place", goal=str(target)):

    with tracer.start_as_current_span("skill.grasp"):
        result = grasp_selector.run(point_cloud)
        momentum.decision(
            type="grasp_selection",
            inputs={"object_id": object_id,
                    "confidence": result.confidence},
            output={"grasp_id": result.id},
        )
        momentum.controller_switch(
            from_mode="position", to_mode="impedance",
            reason="contact_detected",
        )
        arm.execute_grasp(result)
The value curve
Useful in the first hour.
Smarter every month after.
-
Hour one
Drop in a recording of a failed run
run_4412.mcapno code changes
✗ Diverges from run #4411 at
grasp_selection -
Month one
Your engineers confirm each diagnosis
Root cause: grasp_selection✓ confirmed
-
Month six
Ask questions across your whole history
“Why do picks fail on line 2?”
14 of 17 failures happened below 220 lux, vs 2 of 41 above.
The latest from Momentum.
We're looking for a production robot cell.
Validate decision-level diagnosis against real hardware with us. Even a one-time dataset or a single supervised session is genuinely useful.
Get in touch
Momentum is an EPFL Blaze accelerated company.
Stop debugging robots in the dark.
Get in touch. We'll walk through what Momentum sees: the decision that went wrong, and the hardware response that gave it away.
Contact us